Project Overview
I am collaborating with fellow mechanical engineer Euan Chung at NYU Tandon to create a custom 6-degree-of-freedom (6-DOF) robotic arm to deepen my expertise in mechatronics, mechanical design, and hardware integration. The current goal is to support a 5-pound payload at a fully extended reach of 2 feet. While initial control will be handled via a custom mobile application utilizing the ESP32’s onboard Wi-Fi, the overarching goal is to transition the robot to fully autonomous operation.
Mechanics & Mechanical Design
We are currently focused on modeling the arm's components in CAD and performing the torque calculations to define the physical limits of the system. By analyzing the static and dynamic loads, I am determining the exact motor specifications required to ensure the base and shoulder servos can comfortably handle the 5-pound payload and moment of inertia at full extension.
Electronics & Control Architecture
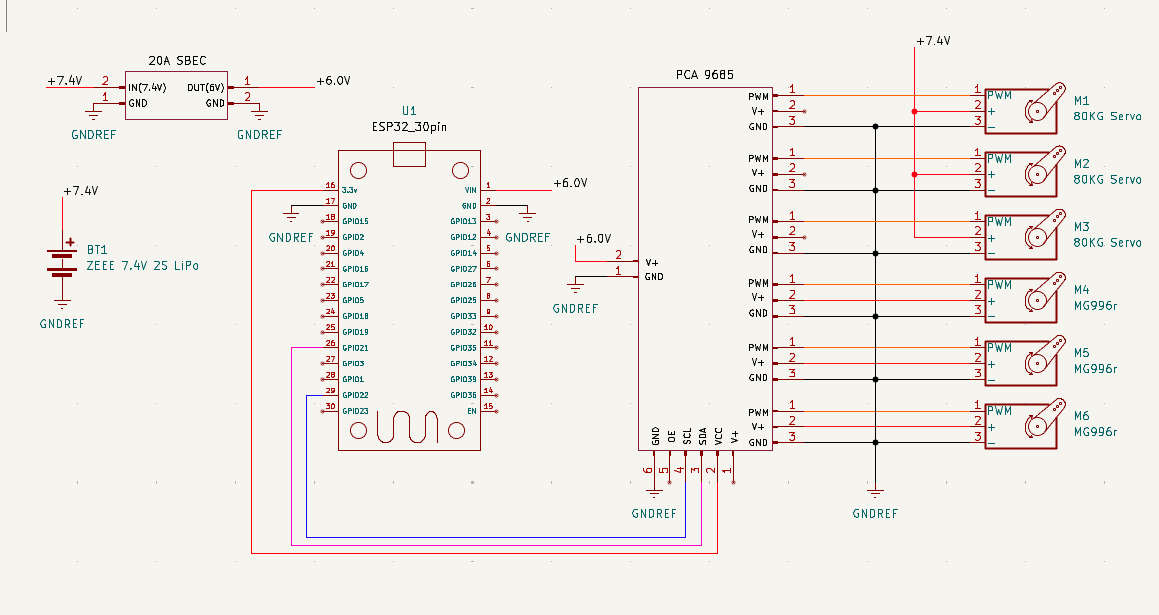
An ESP32 microcontroller drives the control architecture. I designed the custom electrical schematic below to manage signal integration and power distribution across all hardware components. I am currently procuring all hardware for electrical testing.
Future Integration & Autonomy
While current development is focused on the mechanical build and manual kinematic control, the long-term objective is to transition the system to fully autonomous operation. Future work includes mounting the manipulator onto a mobile rover. By integrating computer vision and spatial sensors, the unified system will be programmed to actively detect target objects, autonomously navigate complex environments to reach them, and execute pick-and-place operations.